Sprayer-Robot Detection from Auto-Labeling to Deployment
An object detection pipeline for a sprayer robot, from foundation-model auto-labeling to YOLOv11n edge deployment.
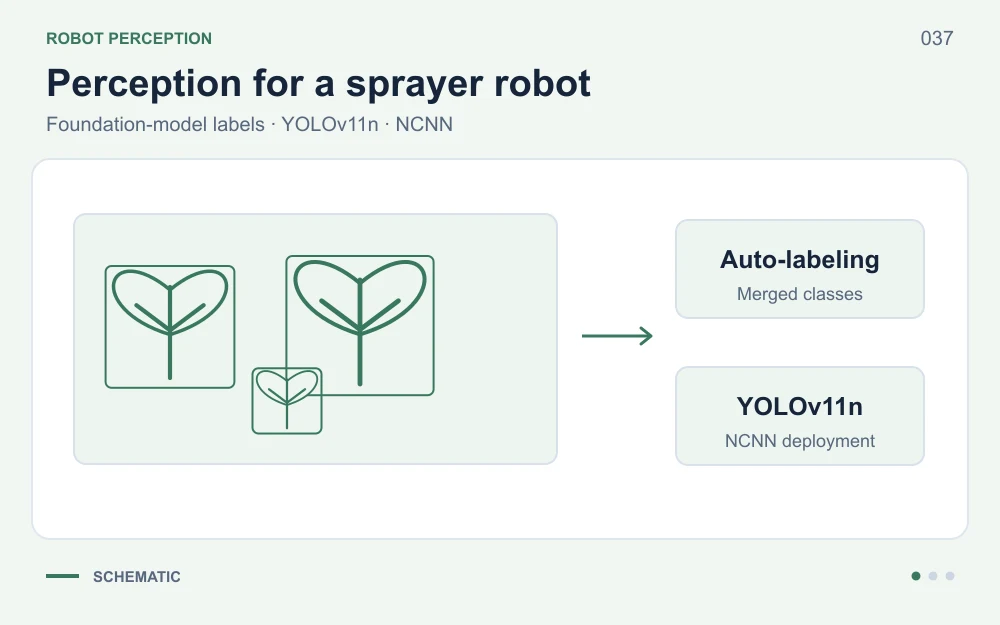
Model Roles
| Model | Purpose |
|---|---|
| YOLOv11 nano | Small deployable detector, quantized with NCNN for CPU-based edge inference |
| SAMURAI | Auto-labels unique marker objects by tracking them through video frames |
| GroundingDINO | Auto-labels faces, shoes, people, and animals from raw images |
| SEEM + SAMv2 | Provides grass, plant, and road labels reused from the segmentation pipeline |
Dataset Merge
| Class ID | Label | Label Source |
|---|---|---|
| 0 | grass | SEEM + SAMv2 |
| 1 | plant | SEEM + SAMv2 |
| 2 | road | SEEM + SAMv2 |
| 3 | person | GroundingDINO |
| 4 | animal | GroundingDINO |
| 5 | marker | SAMURAI |
| 6 | shoes | GroundingDINO |
| 7 | face | GroundingDINO |
Notes
- Reused original COCO labels when available for people and animals.
- Used SAMURAI for the charging-station marker because GroundingDINO struggled with that unique object.