Computer vision & robotics engineer

Computer vision.
Built for the
real world.

I’m Arqam Imtiaz. I turn computer vision research into practical systems for robots, sports AI, and edge devices.

Based in Shenzhen, ChinaLet’s connect
THE ENGINEER BEHIND THE WORK
Arqam Imtiaz
Arqam ImtiazMachine Learning Engineer
7+

Years in computer
vision & robotics

55

Projects to
explore

Data → Edge

From training pipelines
to deployed systems

Selected work

EXPERIENCE ACROSS
Research & industry

01 /Selected work

Featured projects.

Browse all 55 projects

02 /In motion

See the systems work.

Demonstrations from real projects. Watch the behavior, then explore the engineering behind it.

01

Project demonstration

Loads content from LinkedIn when you choose to play.

Video description

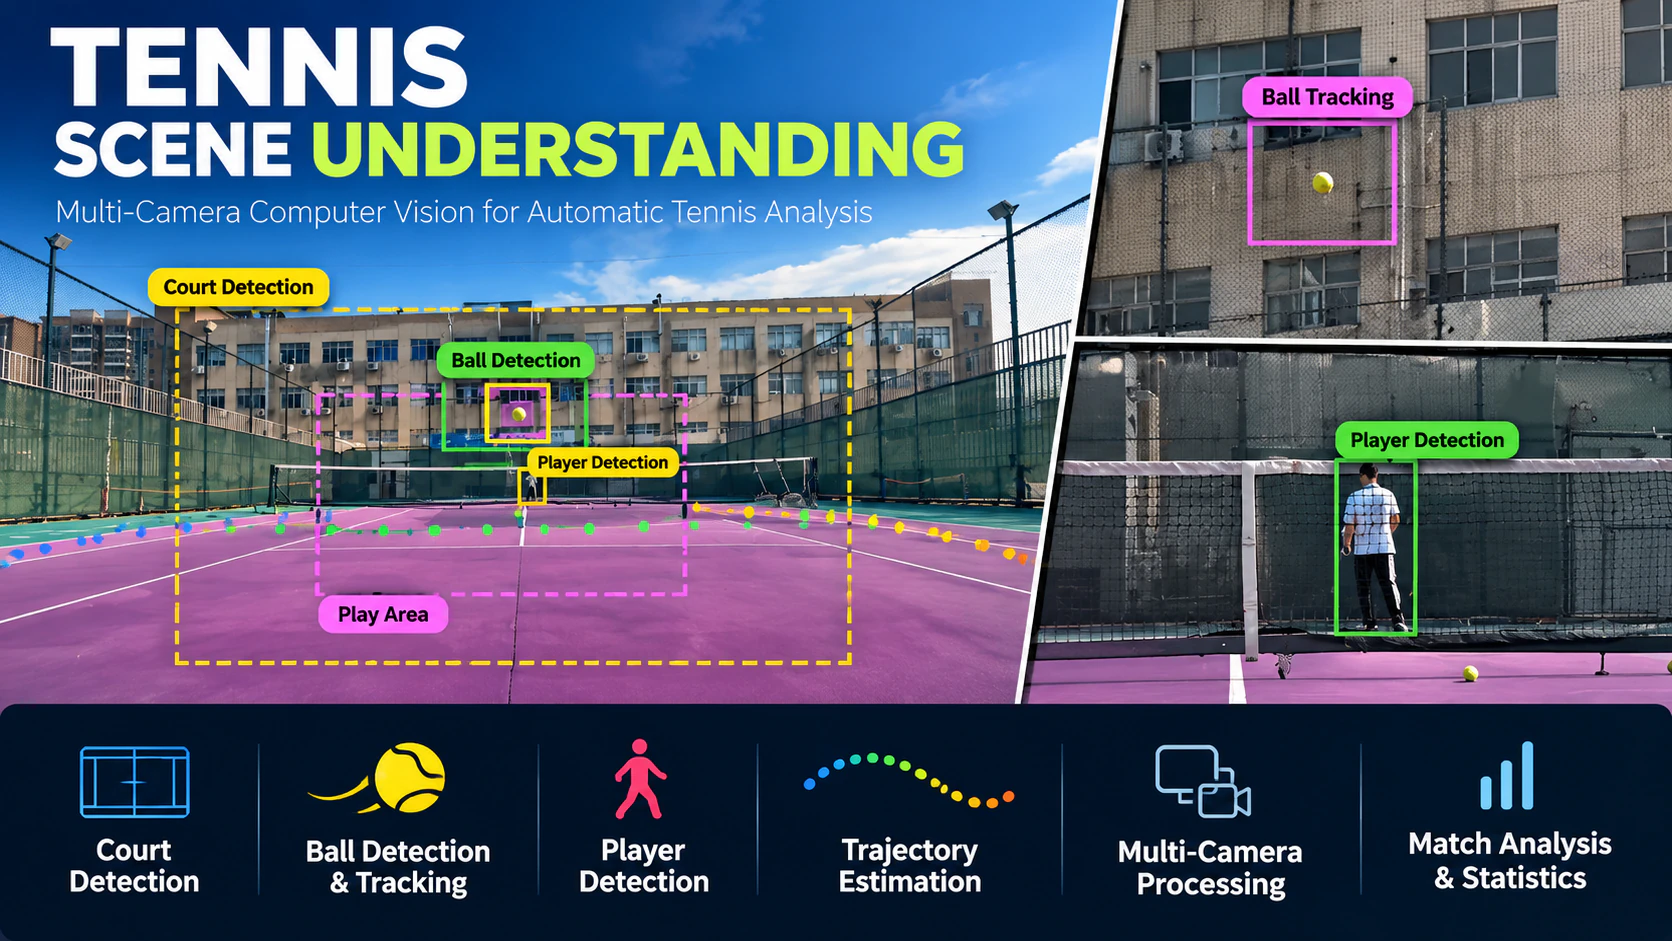
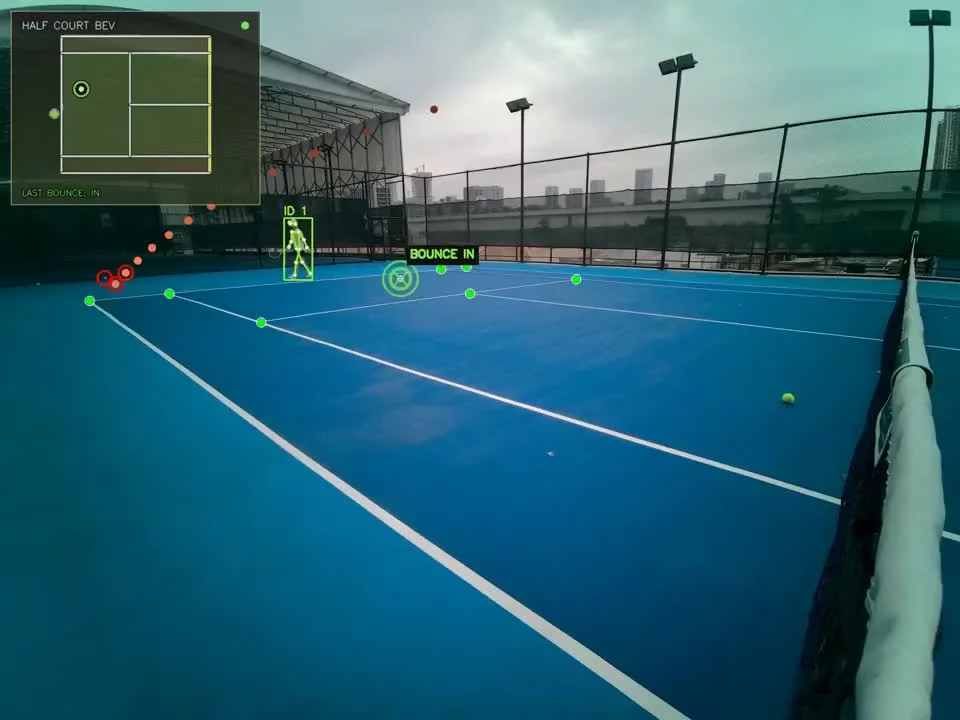
A mounted-camera view of a tennis court includes overlaid court landmarks, player pose, ball positions, and a reconstructed trajectory. A court map summarizes the spatial view, and on-screen annotations indicate bounce events.

Real-time tennis analysis and automated line calling running on the self-contained edge unit.Open on LinkedIn
02

LinxAI Intelligent Technology

From simulation to four feet on the ground

Project demonstration

Loads content from LinkedIn when you choose to play.

Video description

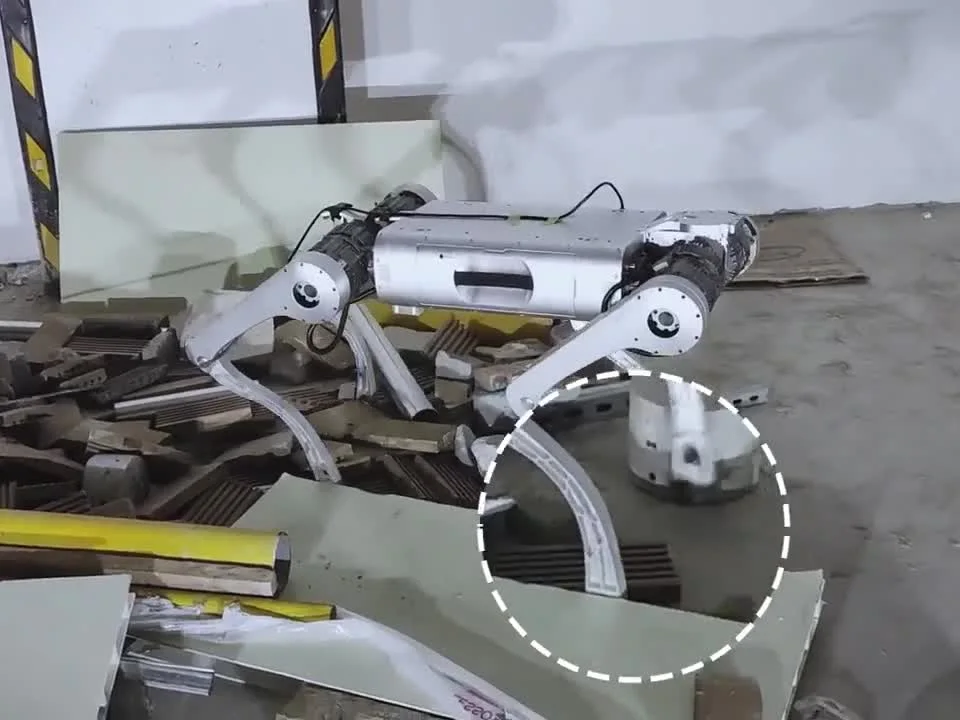
The custom quadruped walks across physical test terrain using a policy based on proprioception. The video shows stairs, loose material, and changing support surfaces. The accompanying architecture diagram describes how training uses a privileged critic while the deployed actor uses robot observations.

The learned locomotion policy running on the physical quadruped across varied terrain.Open on LinkedIn

03 /Experience

A career built
around perception.

Sports AI, autonomous robots, 3D vision, and the engineering that brings them into the real world.

Companies, roles & projects
Dec 2025 – PresentCurrent role

Enhanced Robotics (Tenniix Official)

Algorithm Engineer

Own the visual-perception lifecycle for real-time tennis AI systems.

  • Built temporal ball and person-attribute models, court keypoint detection, and dual-camera geometric fusion.
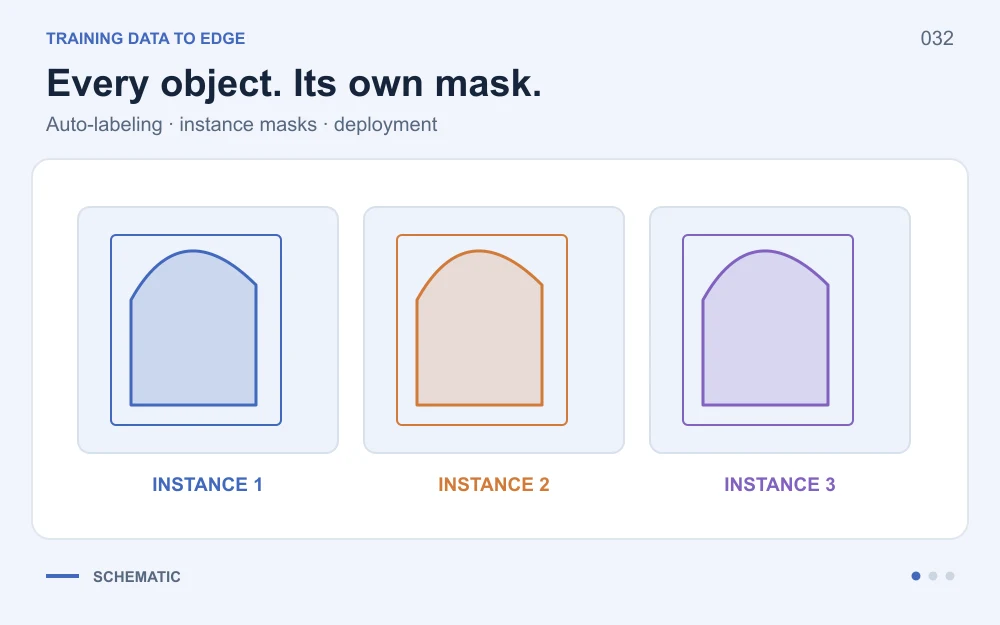
  • Developed auto-labeling and model export workflows for edge deployment and continued data iteration.
Oct 2024 – Dec 2025

Benign Innovations (Co-founding Startup)

Algorithm Engineer

Led applied perception R&D for tennis analytics and autonomous lawn-care robotics.

  • Integrated court geometry, ball and player tracking, pose, and ReID into an on-device tennis analytics stack.
  • Built auto-labeling, segmentation, and deployment pipelines for lawn-care robot perception.
Dec 2023 – Oct 2024

LinxAI Intelligent Technology Co., Ltd.

Algorithm Engineer

Developed deep-reinforcement-learning locomotion policies and simulation-to-robot transfer workflows.

  • Trained proprioception-only locomotion policies in Isaac Gym and transferred them to a custom quadruped.
  • Developed flat- and rough-terrain policies; published a physical-robot demonstration including 15 cm stairs.
May 2021 – Oct 2023

XPENG Robotics

Deep Learning Engineer

Built and optimized perception workflows across indoor 3D vision, robot interaction, and autonomous systems.

  • Developed depth, segmentation, human perception, and robot-interaction models.
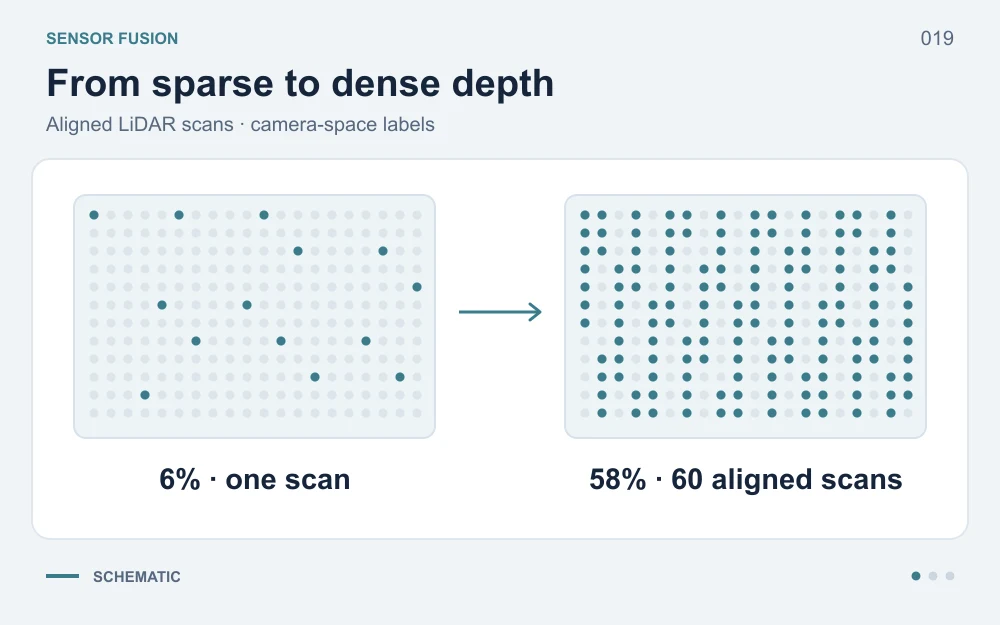
  • Built a camera–LiDAR fusion pipeline that increased depth-label density from 6% to 58% using 60 scans.

04 /Expertise

From the data
to the device.

I work across the full ML lifecycle, connecting data quality, model behavior, hardware constraints, and product needs.

01

Production vision

Real-time detection, tracking, temporal models, keypoints, segmentation, and multi-camera geometry.

  • Detection & tracking
  • Temporal vision
  • Multi-camera systems
02

Data flywheels

Auto-labeling, active learning, hard-example mining, synthetic data, and quality auditing.

  • Auto-labeling
  • Dataset curation
  • Quality loops
03

Model to edge

Training, benchmarking, ONNX and TensorRT export, quantization, profiling, monitoring, and iteration.

  • PyTorch
  • ONNX / TensorRT
  • Performance profiling
04

Robotics & 3D

Depth, pose, point clouds, camera calibration, simulation-to-real transfer, and spatial perception.

  • 3D perception
  • Robot learning
  • Sensor geometry
TOOLS I WORK WITH
PythonC/C++PyTorchPyTorch LightningTensorFlowTensorRTMATLABGitDockerLinuxOpenCVONNXMLflow

05 /Education

The foundations.

2017 – 2019

Xiamen University

Master of Engineering in Computer Technology

Xiamen, China

Thesis: Deep discriminative feature learning with a multi-level network for person re-identification.

2012 – 2016

COMSATS University

Bachelor of Science in Electrical Engineering

Islamabad, Pakistan

Final project: vision-based shooting-target accuracy measurement for a training range.

HAVE A PROJECT OR AN OPPORTUNITY IN MIND?

Let’s build
something that works.

Let’s talk about perception, a product challenge, or an idea worth exploring.

Start a conversation