Uncertainty Modeling for Stereo Depth Estimation
A stereo depth estimation project focused on modeling both aleatoric and epistemic uncertainty for safer real-time depth prediction.
Approach
- Trained a Deep Learning Cost Volume based Stereo Depth Estimation Algorithms on custom Sparse and Dense datasets for performance comparison
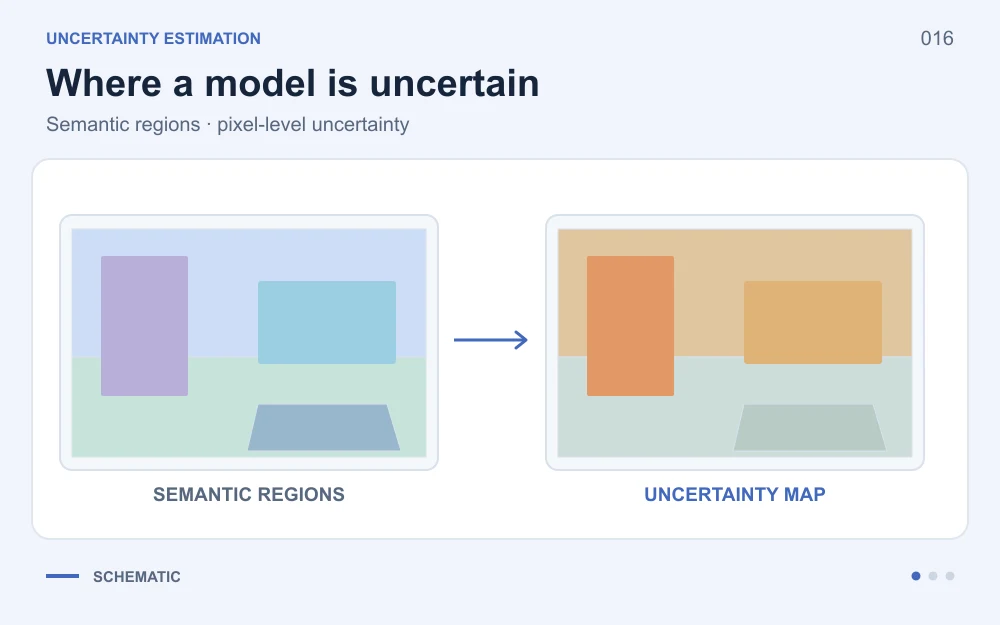
- Aleatoric Uncertainty Modelling by learning Variance by adding a small Variance Network to current Depth Estimation Algorithm and training with negative log-likelihood (NLL) loss
- Initially learning Epistemic Uncertainty using MC-Dropout Method (Requires multiple Forward passes)
- Explored Sampling-free Epistemic Uncertainty Estimation using Evidential Deep Learning
- To Deploy sampling free Uncertainty Estimation to Filter Uncertain Depth Prediction on a real time system
Goal
Deploy sampling-free uncertainty estimation to filter unreliable depth predictions in a real-time robotics perception system.