Indoor Semantic Segmentation
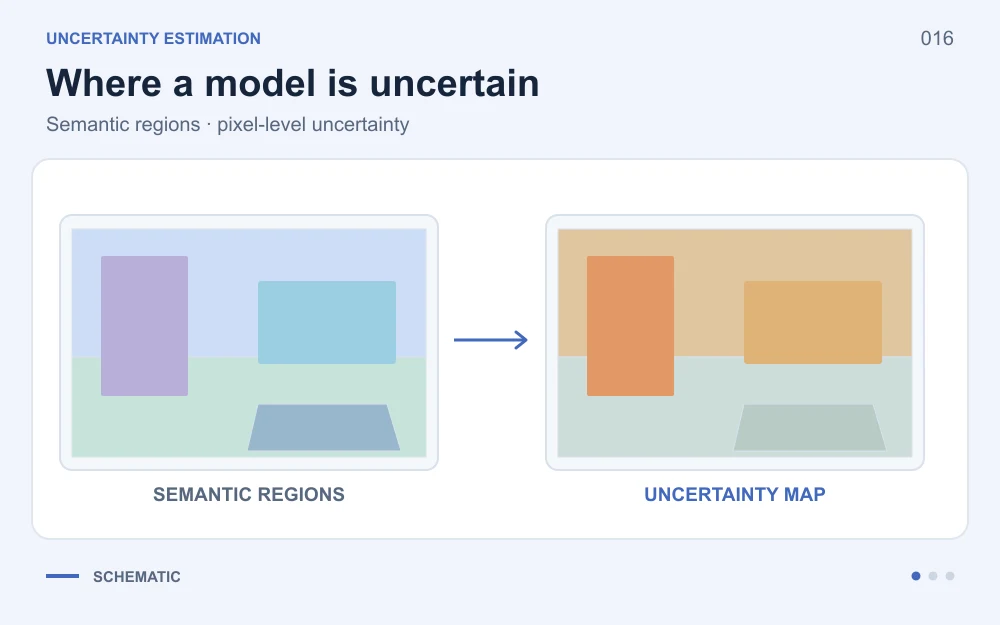
An indoor semantic segmentation project comparing transformer-based and CNN-based segmentation models on custom robotics data.
Model Comparison
| Model Family | Example | Evaluation Focus |
|---|---|---|
| Transformer-based | SegFormer | Accuracy with mIoU |
| CNN-based | DDRNet | Real-time speed with FPS |
Contributions
- Selected DDRNet for indoor custom-data segmentation.
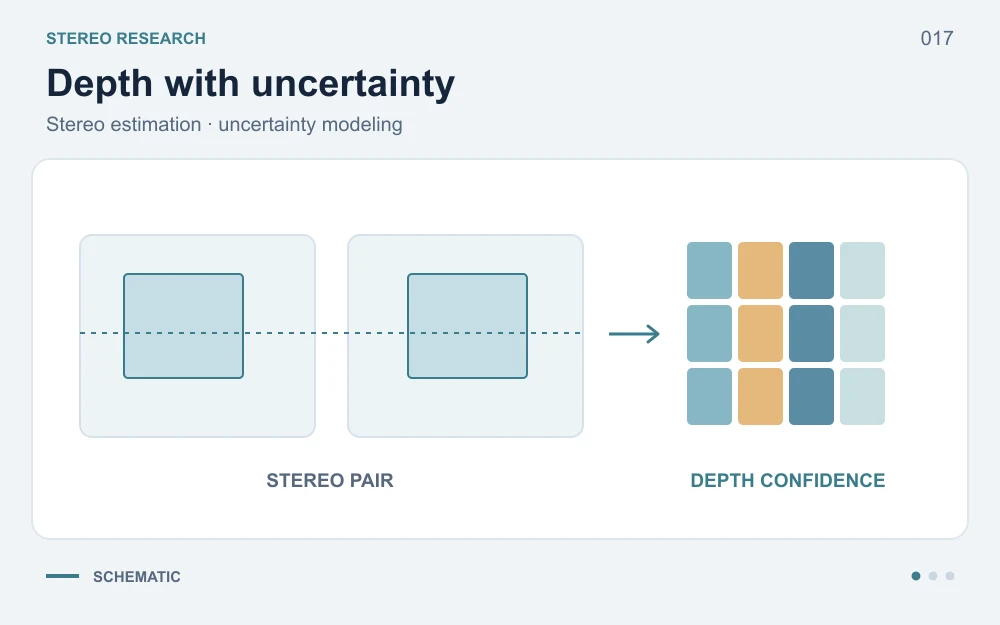
- Used 2D semantic segmentation to handle transparent or glass-like doors and walls where depth estimation is limited.
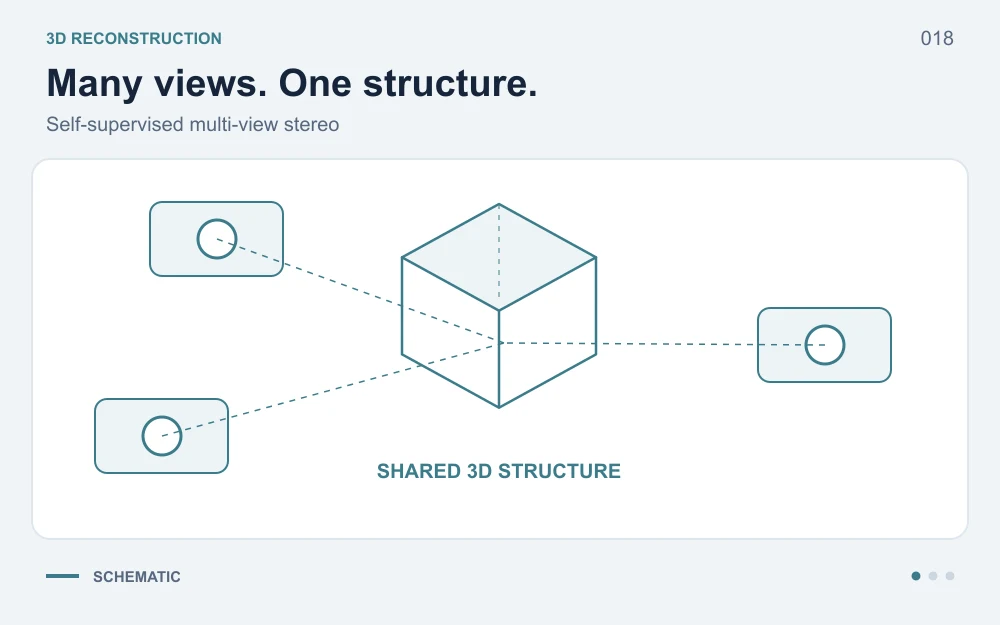
- Projected segmented image regions back into point clouds for more accurate semantic 3D perception.