Robot-Arm Segmentation for Background Filtering
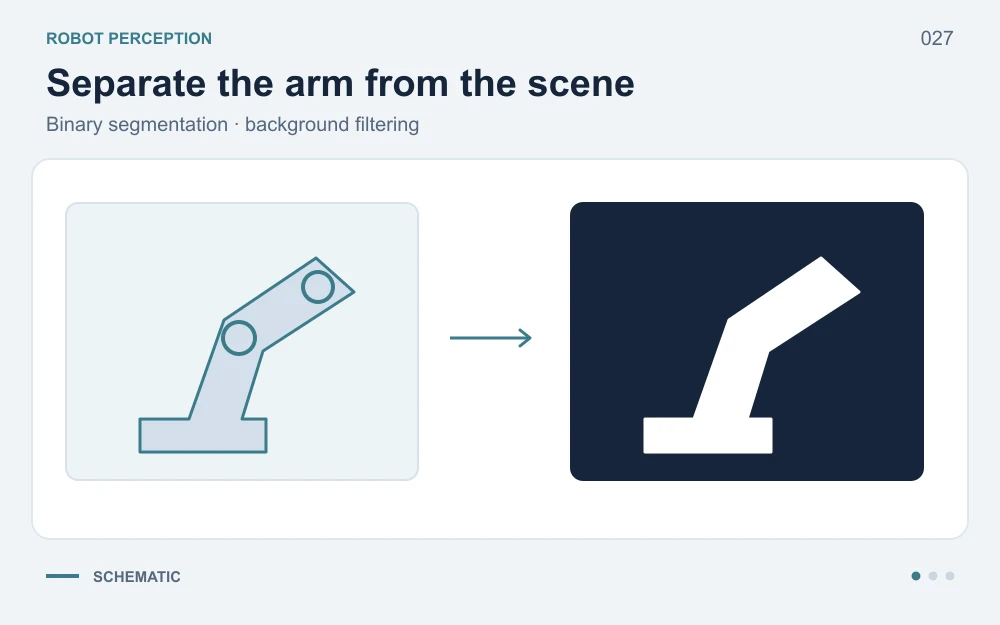
A binary semantic segmentation pipeline for separating a robotic arm from the background.
Work Completed
- Completed the model training pipeline.
- Prepared labeling documentation and monitored annotation quality.
- Improved the algorithm iteratively with additional data.
Goal
Generate clean robotic-arm masks that can be used to filter the arm from visual perception outputs.