Ground Segmentation for Obstacle Avoidance
A point-cloud processing pipeline for ground segmentation and obstacle extraction in outdoor robot navigation.
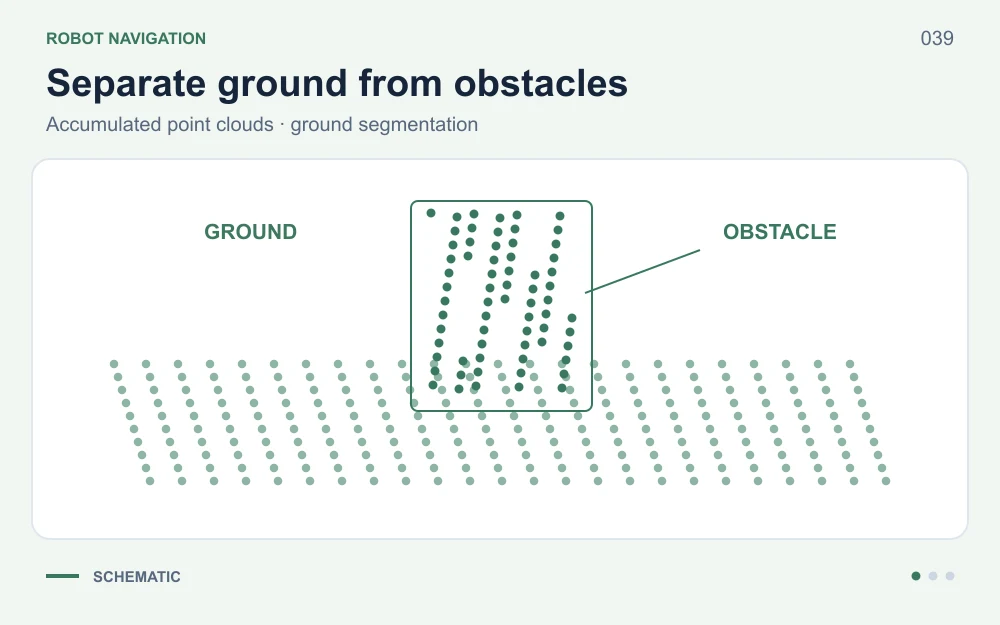
Pipeline
- Accumulate and align point-cloud frames using LiDAR-Inertial Odometry and wheel odometry.
- Segment ground points with CSF.
- Filter dynamic points with SOR.
- Treat non-ground objects within 2 feet of the ground as obstacles.
- Ignore points above 2 feet, such as tree or plant canopies, for obstacle-avoidance purposes.
Algorithms
| Short Name | Algorithm |
|---|---|
| CSF | Cloth Simulation Filter |
| SOR | Statistical Outlier Removal |
Runtime Behavior
The algorithm keeps accumulating point clouds until interrupted, then runs ground segmentation and dynamic-point filtering on the accumulated cloud.