Hybrid Deep RL and MPC for Quadruped Locomotion
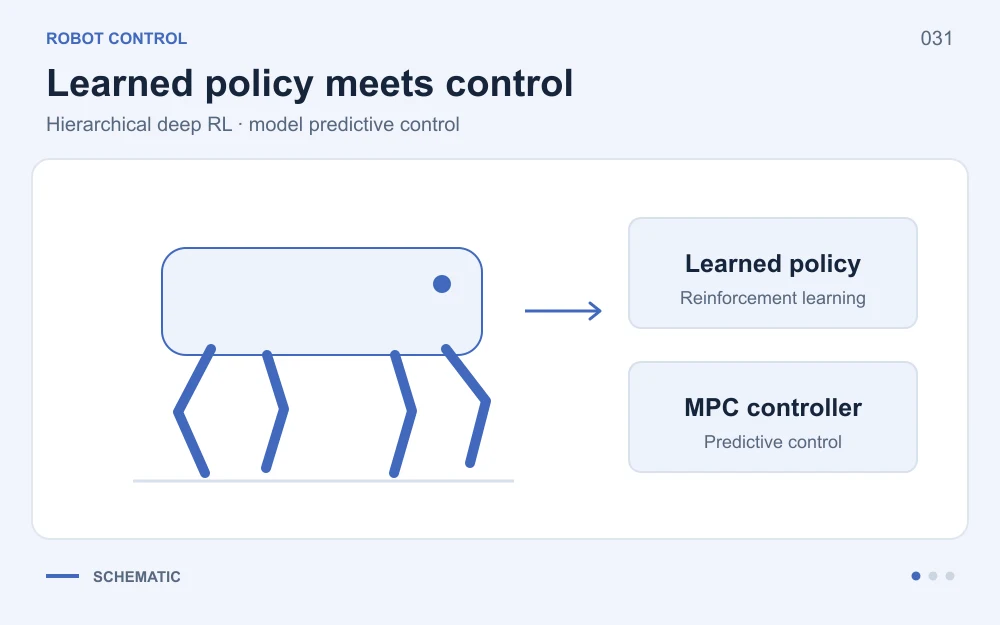
A hierarchical quadruped locomotion framework that combines Deep Reinforcement Learning with Model Predictive Control.
Motivation
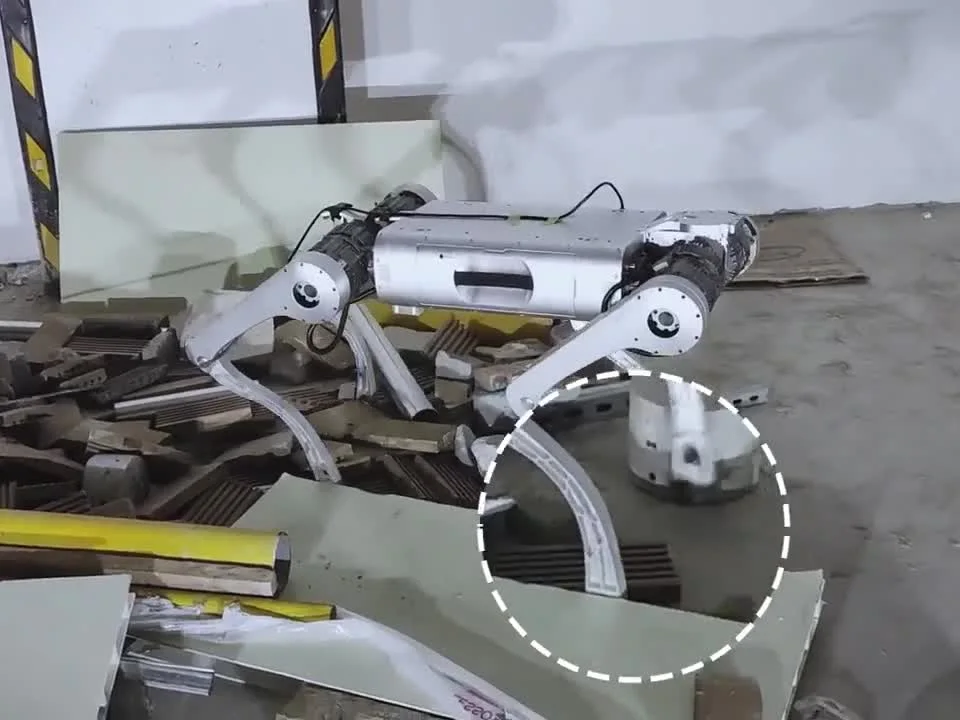
Pure end-to-end reinforcement learning can be hard to interpret and may introduce safety risks. Hybrid approaches are more reliable because of their higher level of interpretability and robustness in terms of stability because of their use of well-known first principles.
Controller Design
| Layer | Role |
|---|---|
| High-level centroidal policy | Learns motion-level control decisions |
| Low-level leg controller | Executes stable leg movement and contact behavior |
Training Setup
Our approach is to combine Deep Reinforcement Learning (RL) and Tradtional Model Predictive Control (MPC) to train our controller policy in parallel way using ISAAC Gym simulator for scalable policy development.