Deep RL Locomotion on the Unitree A1
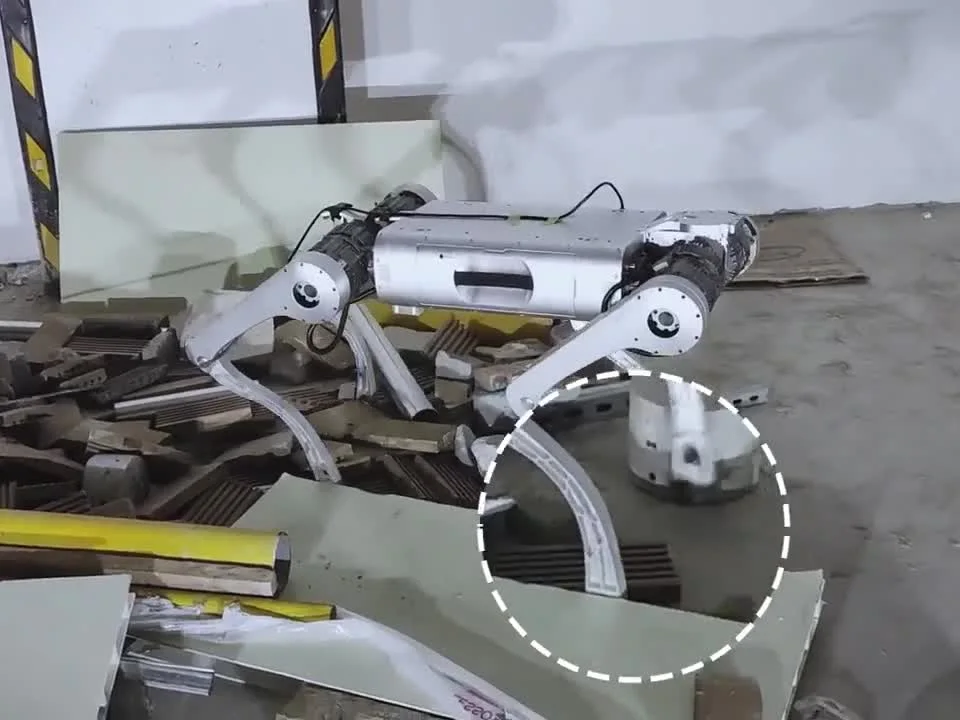
Deep reinforcement learning experiments for quadruped locomotion on a Unitree A1 robot.
Training Stages
| Stage | Inputs | Terrain | Result |
|---|---|---|---|
| Blind flat-terrain policy | Proprioception only | Flat ground | Deployed on Unitree A1 |
| Blind rough-terrain policy | Proprioception only | Rough terrain | Deployed on Unitree A1 |
| Vision-guided policy | Proprioception + depth image | Complex terrain | Trained in Isaac Gym |
Notes
- Used Isaac Gym for simulation-based policy training.
- Tested proprioceptive input with 48D state features.
- Planned additional exteroceptive inputs including RGB-D, LiDAR, heightmaps, and occupancy voxels.