Feature Matching for Visual Odometry and SLAM
A survey and comparison of feature matching methods for visual odometry, visual localization, and SLAM.
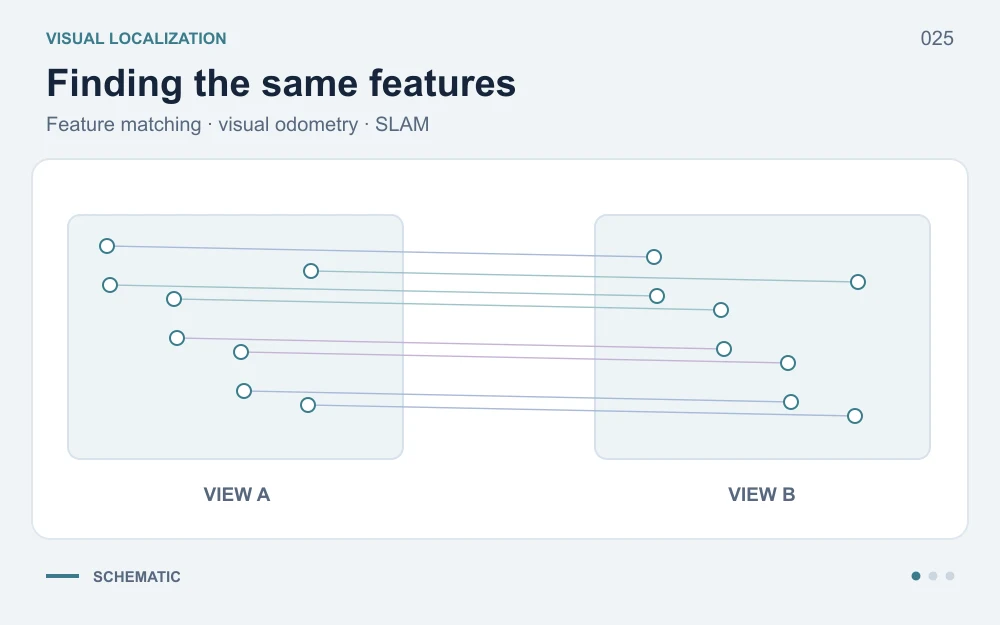
Methods Compared
| Family | Methods |
|---|---|
| Traditional | SIFT, ORB |
| Deep learning | LoFTR, QuadTree Attention, DeepMatcher |
Long-Term Localization
Initial methods struggled in long-term localization conditions, so the study expanded to:
- Root-SIFT for stronger traditional descriptors.
- DISK for learned feature descriptors.
- Recent deep methods such as PoSFeat and SCFeat.